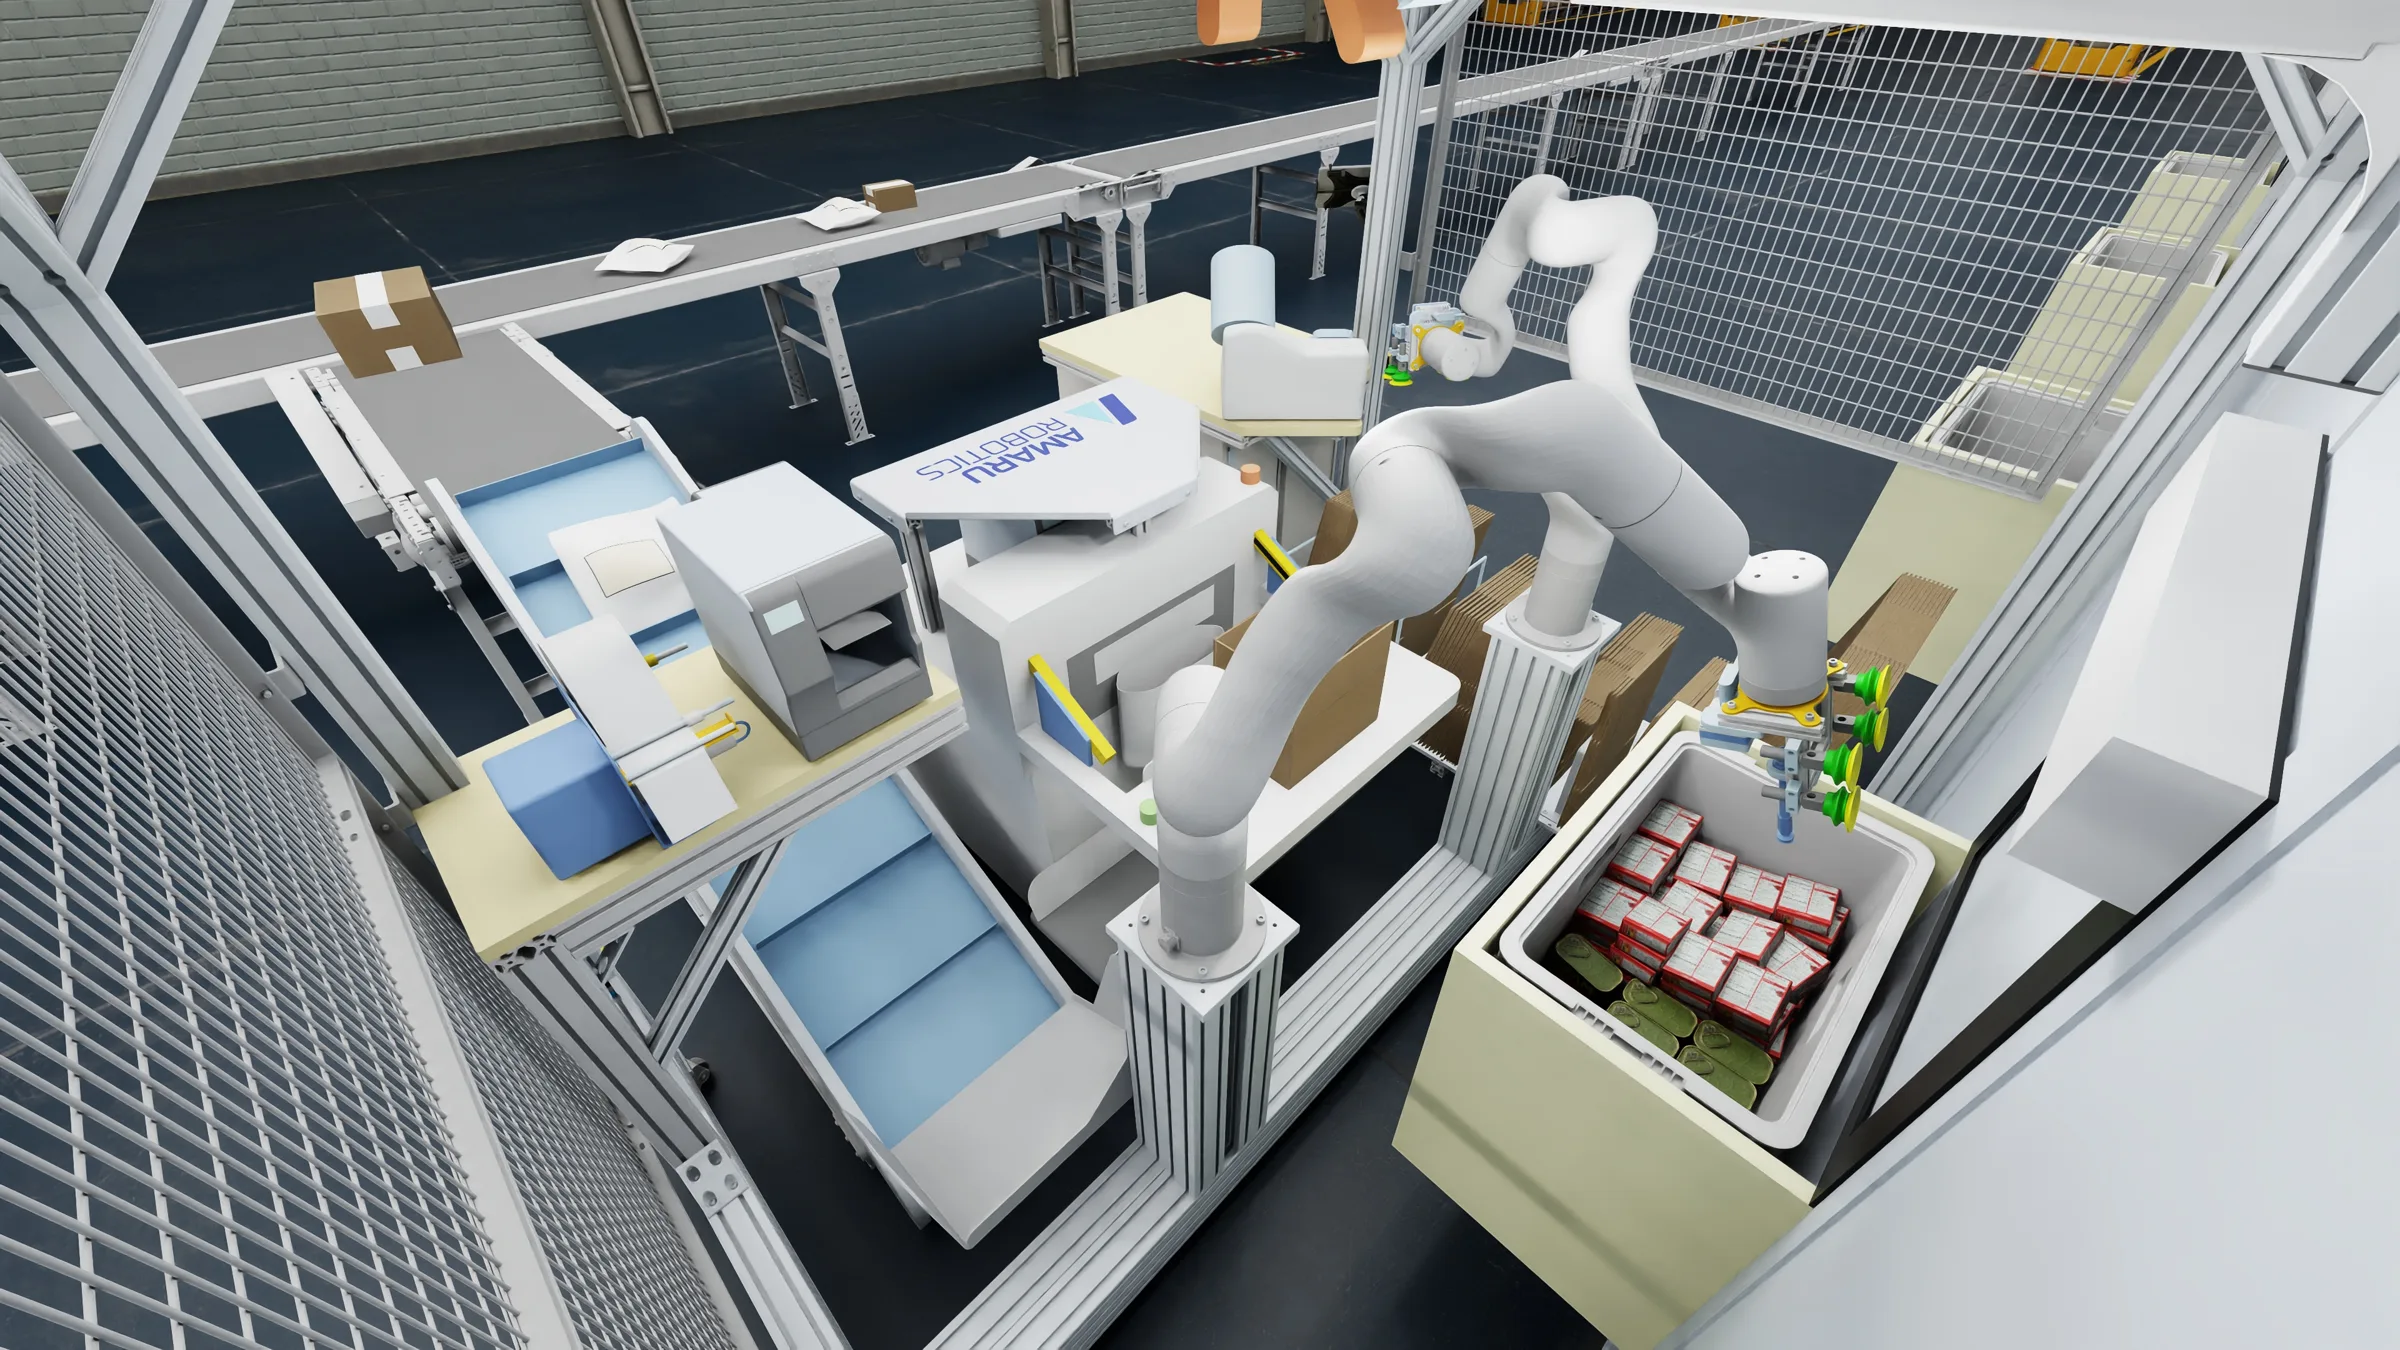
We are hiring a senior engineer who can train modern manipulation policies and make them work reliably in the real world. This is a software and AI role.
What you'll do
- Train and deploy manipulation policies (imitation learning, visuo-motor policies, keypose prediction, RL, sim-to-real) for dual-arm packing.
- Build and improve the perception stack: detection, segmentation, and pick-and-place reliability in production.
- Own the loop from real-robot data collection to training, evaluation and deployment.
- Deploy on-site with us (light travel, about 10–20%, plus on-call) and judge what is reliable and performant in a live customer facility.
You have
- Senior-level experience (roughly 3–5+ years) building robotics or ML software, with strong Python.
- Hands-on experience getting a robot working in a real commercial or industrial deployment. Any robot counts (arms, drones, mobile), as long as it went beyond a lab or side project.
- Fluency with modern manipulation and computer-vision methods, and with agentic coding tools (Claude Code, Codex).
Nice to have
- Deployed learned policies or perception on real robots.
- Motion planning (e.g. cuRobo), segmentation (e.g. SAM2), detection, sim-to-real, C++.
- Early-stage startup experience.
Compensation: $150K–$280K base + meaningful early-stage equity. Don't check every box? Apply anyway.
Apply for this role